Autonomous Robot
Autonomous robot with advanced longitudinal control
A robot built from scratch, with an intelligent longitudinal control system based on fuzzy logic and an FLC-PID controller for autonomous driving.
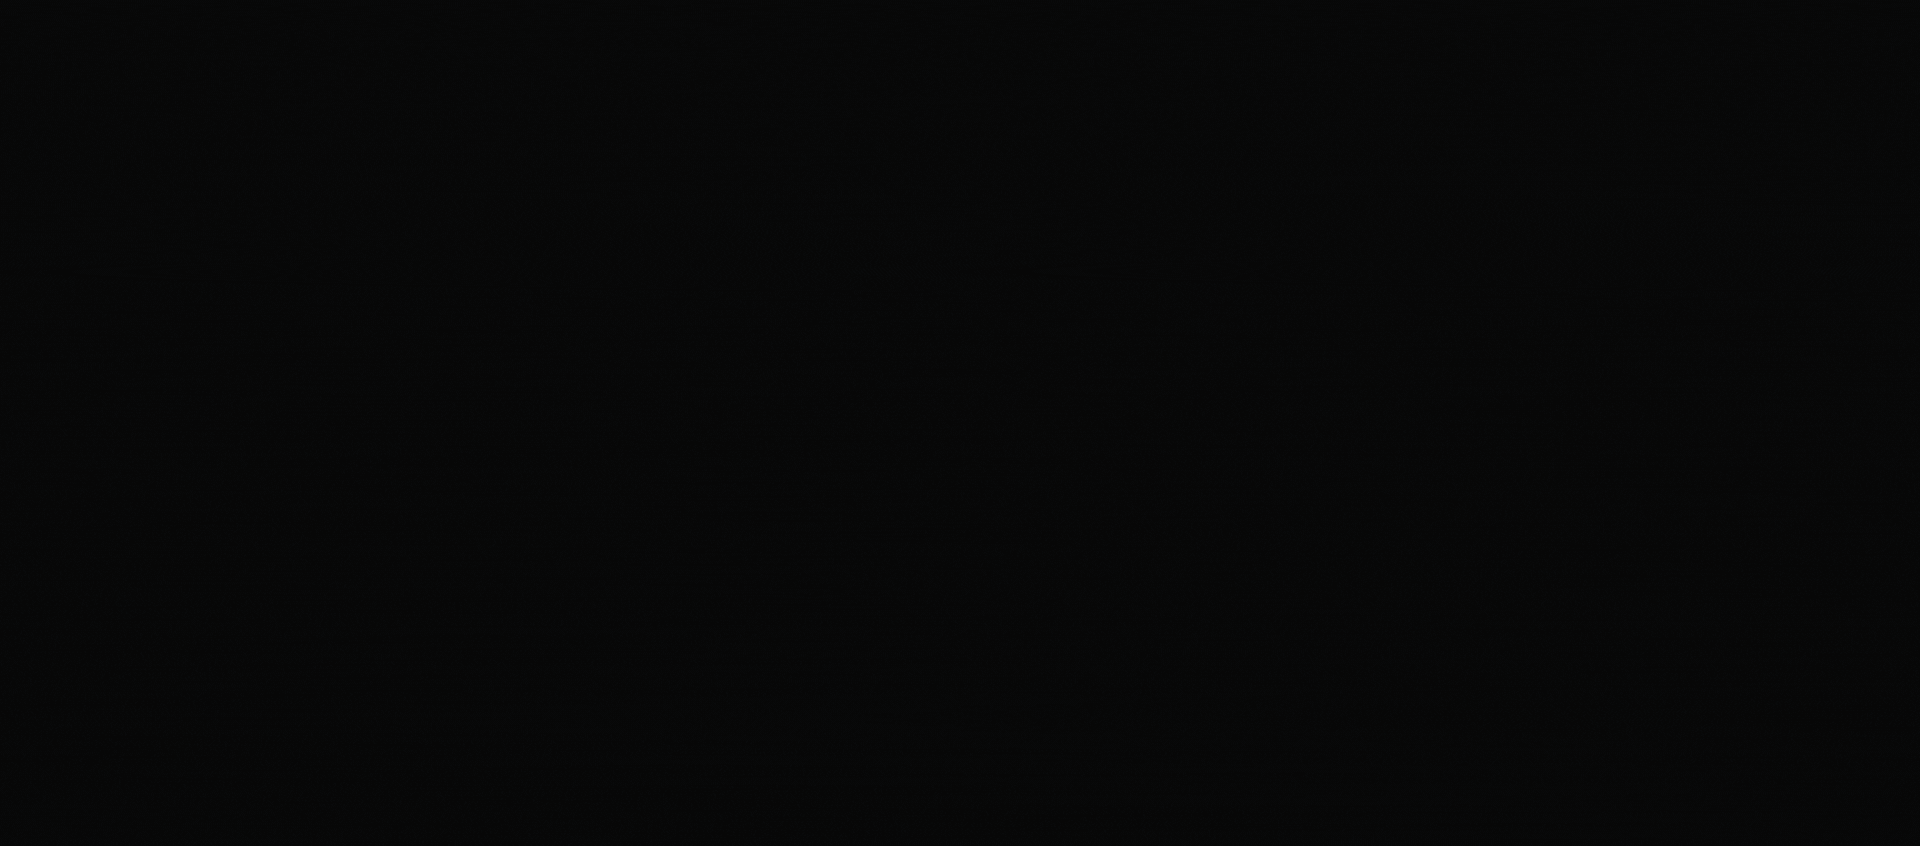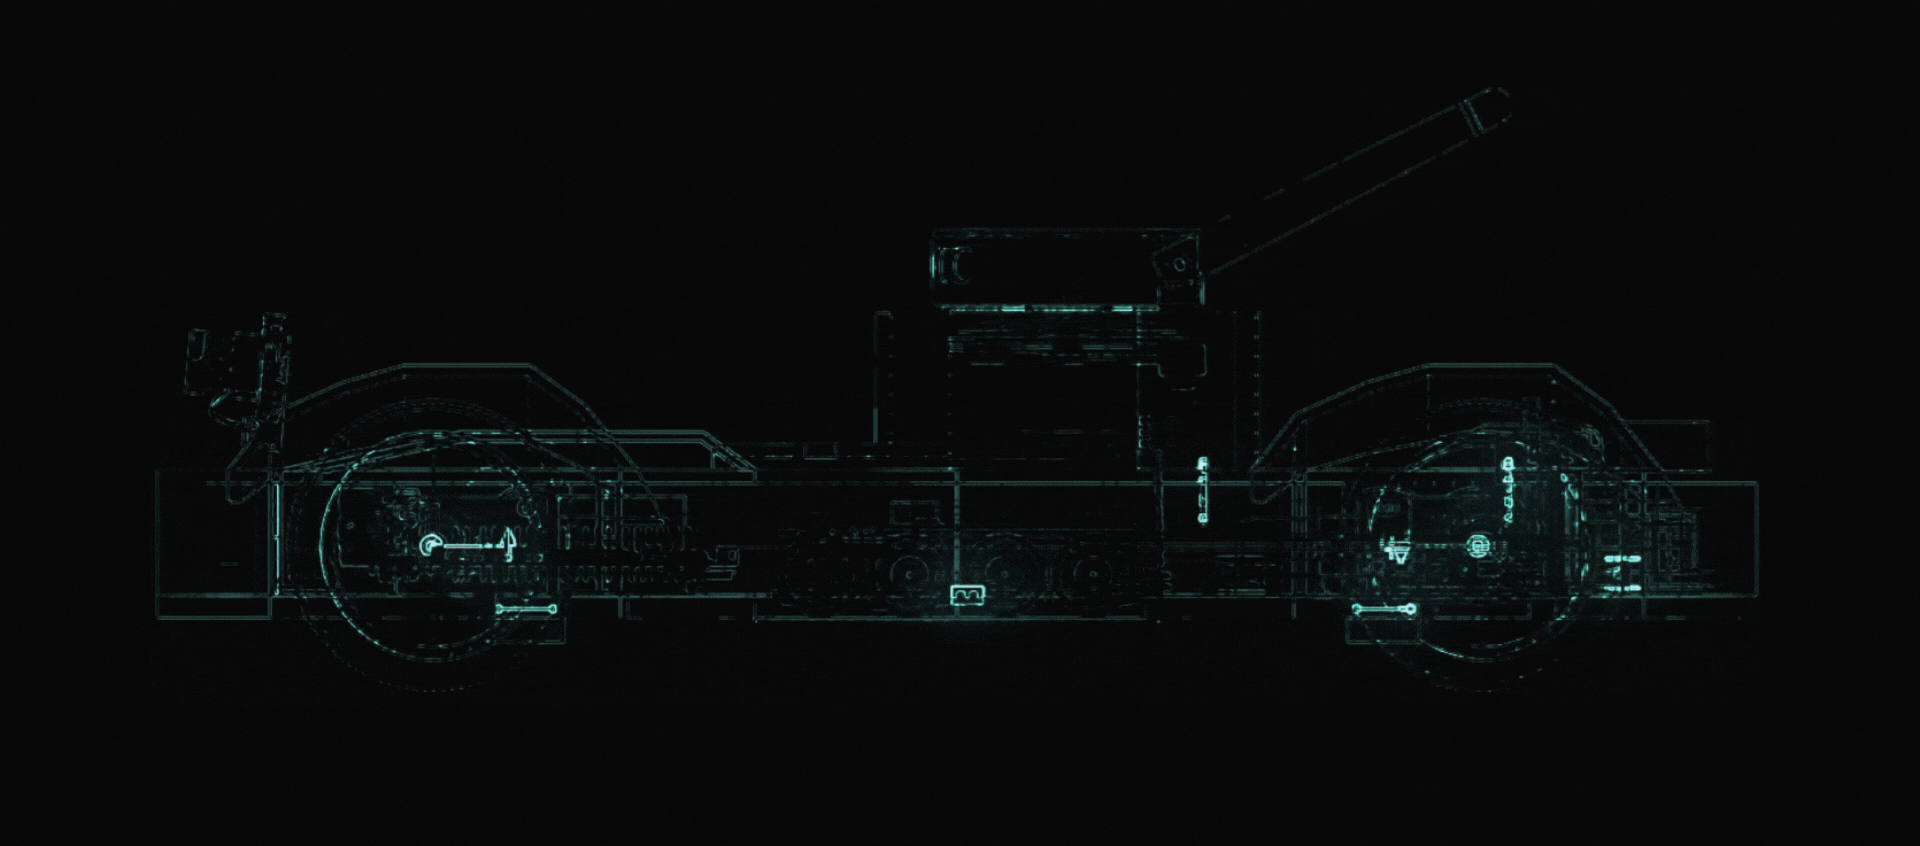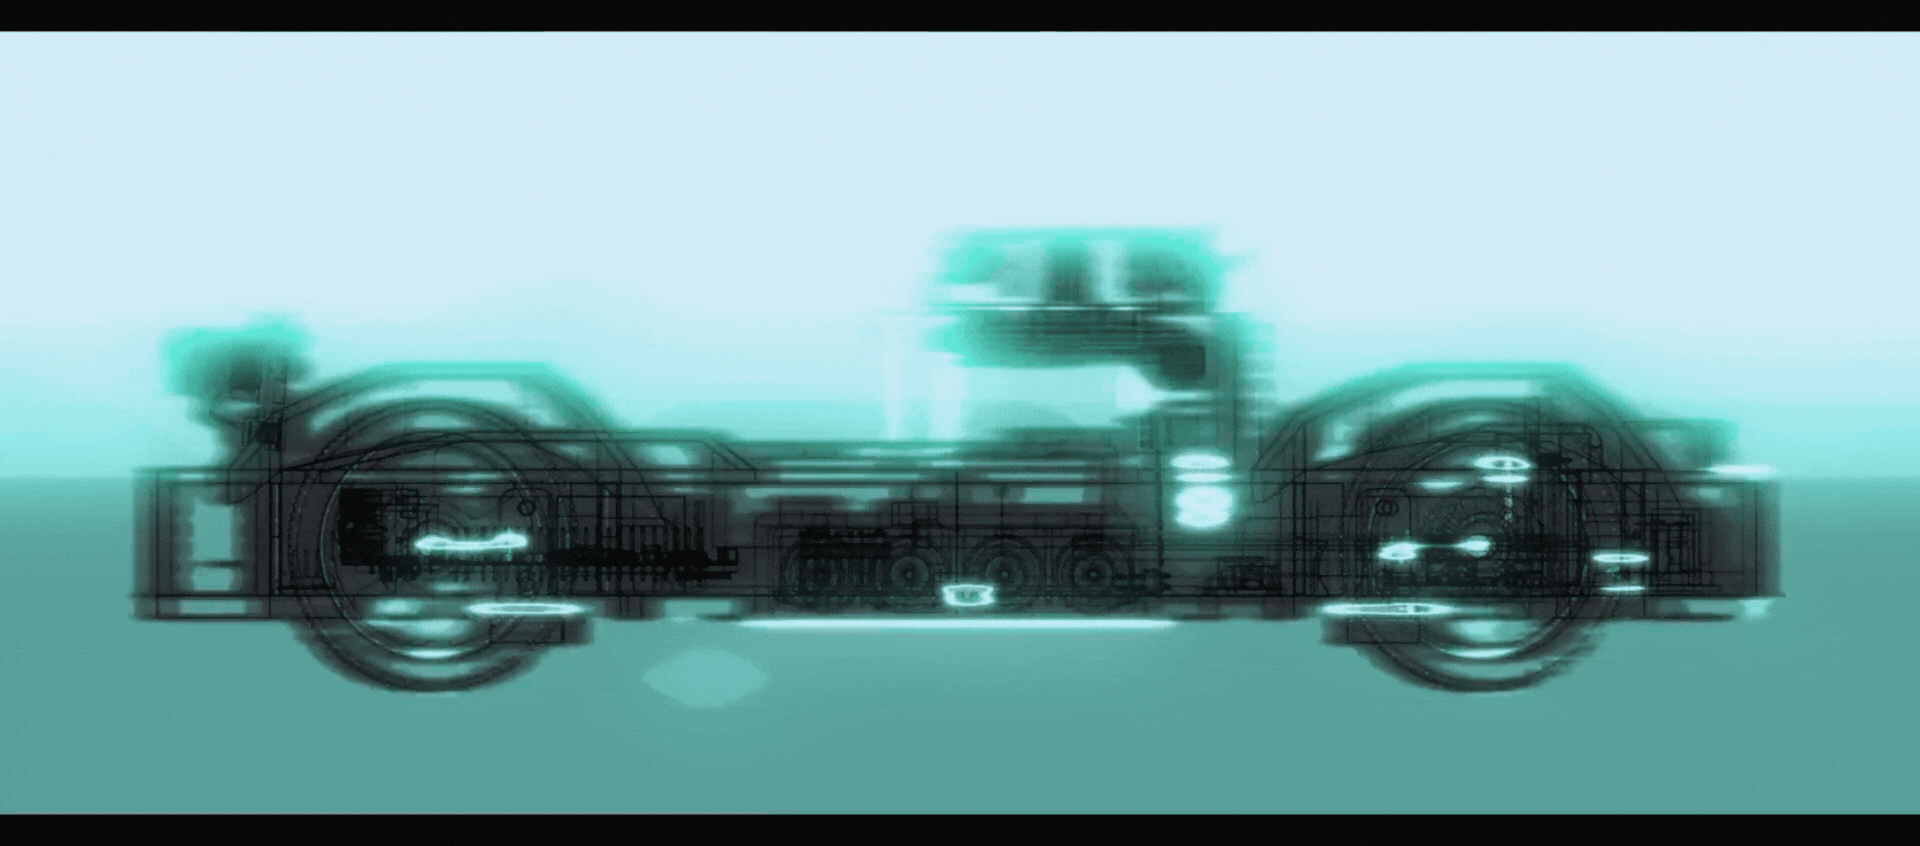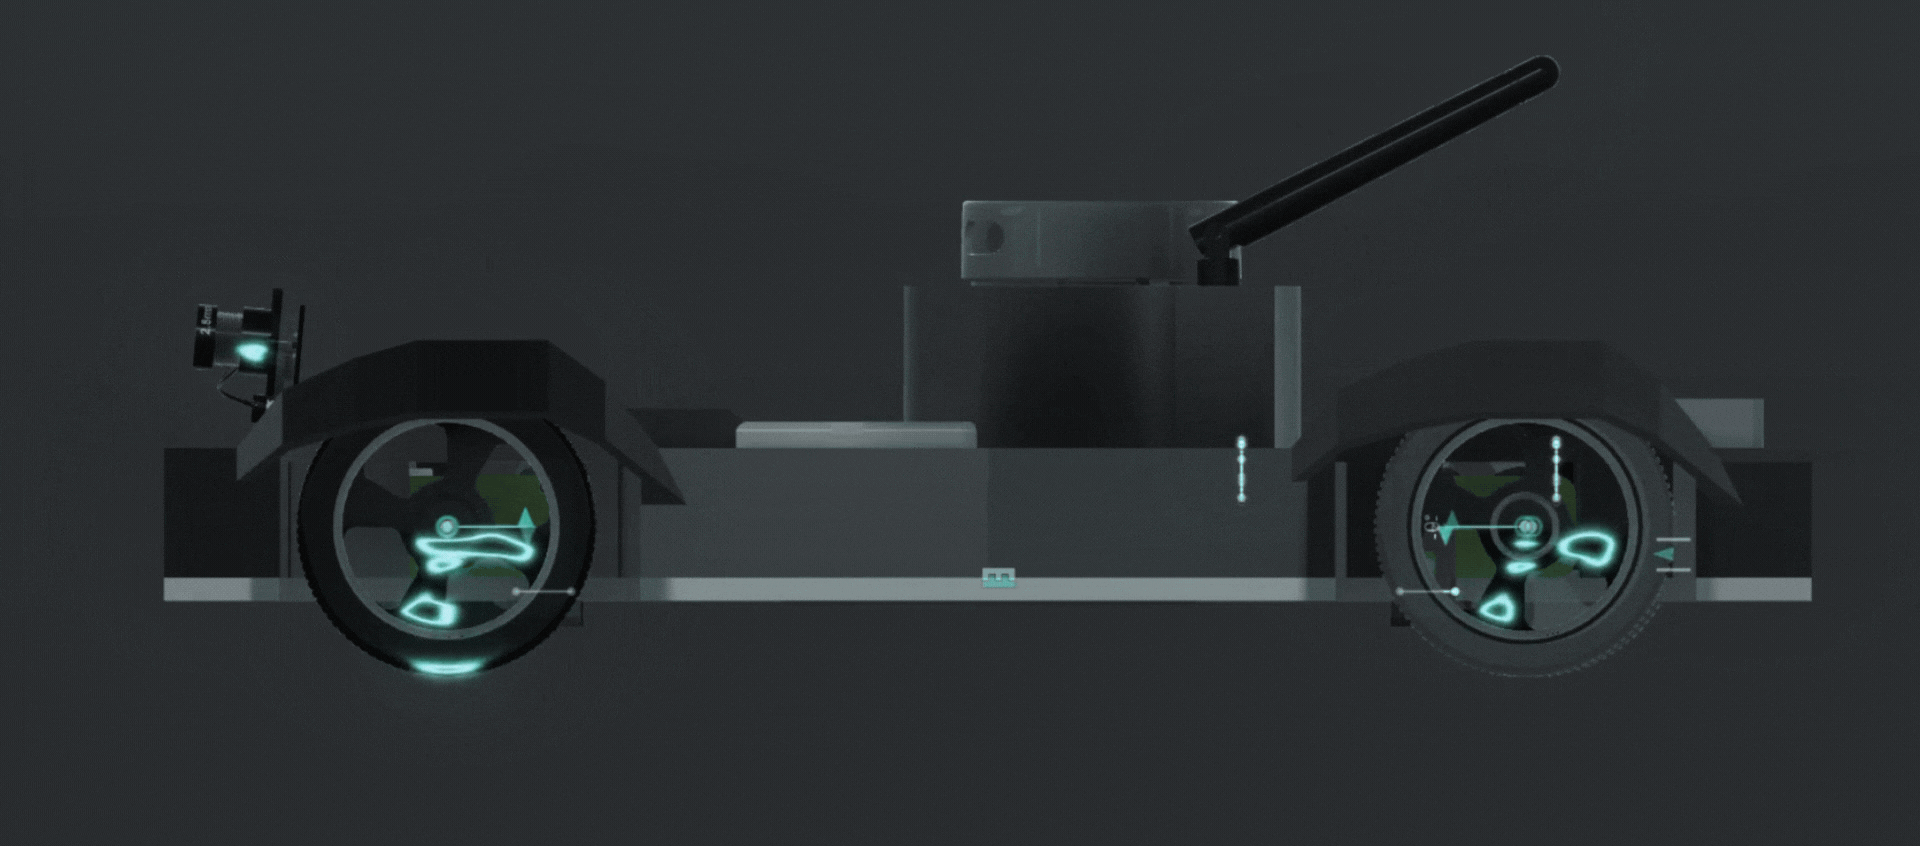
Chassis design
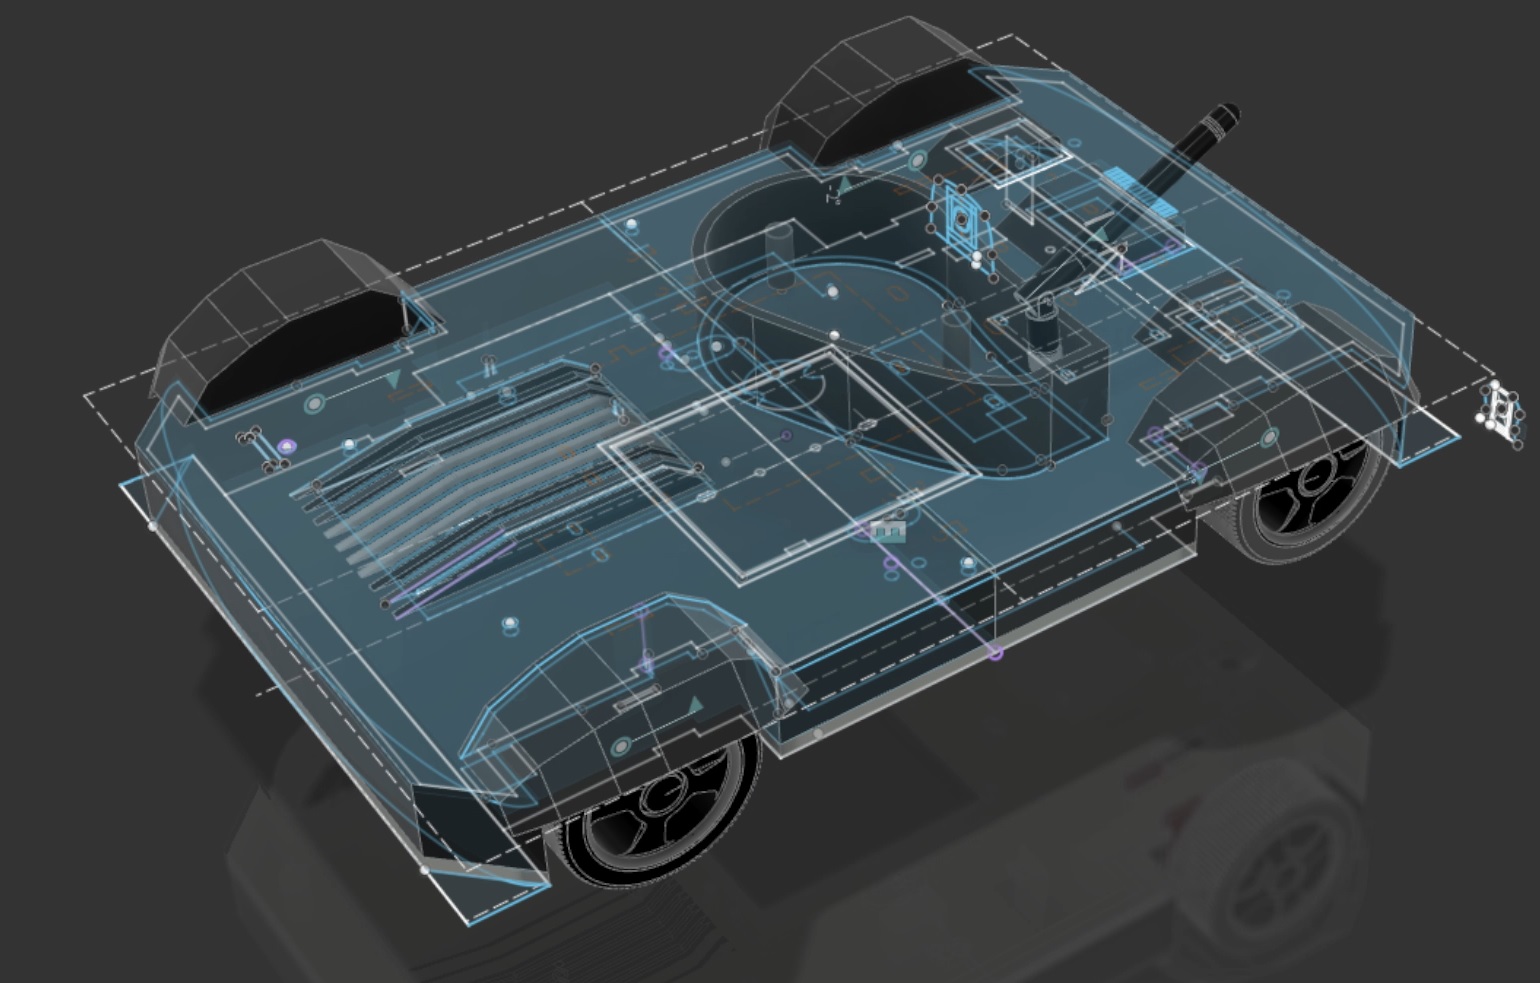
Robot components
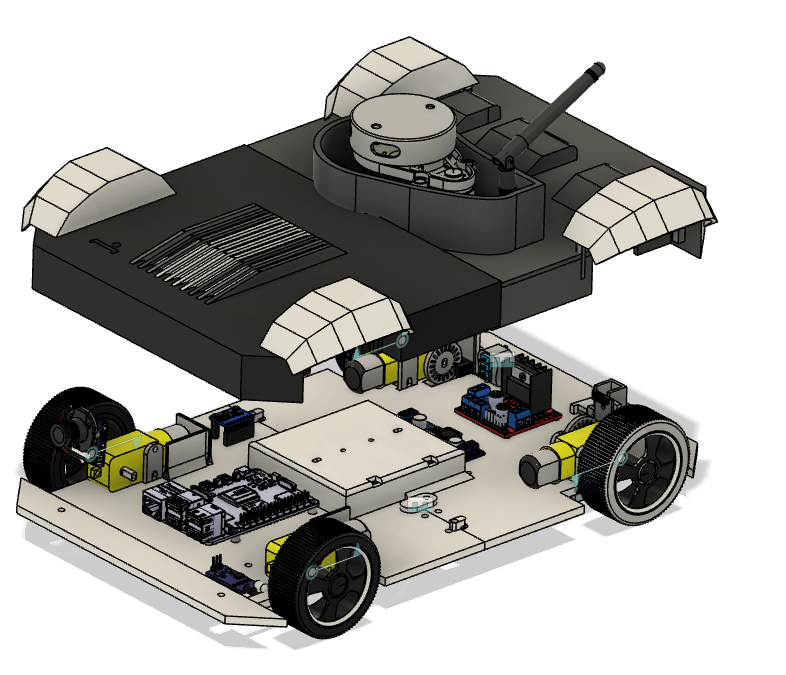
From motors to algorithm — everything built by hand
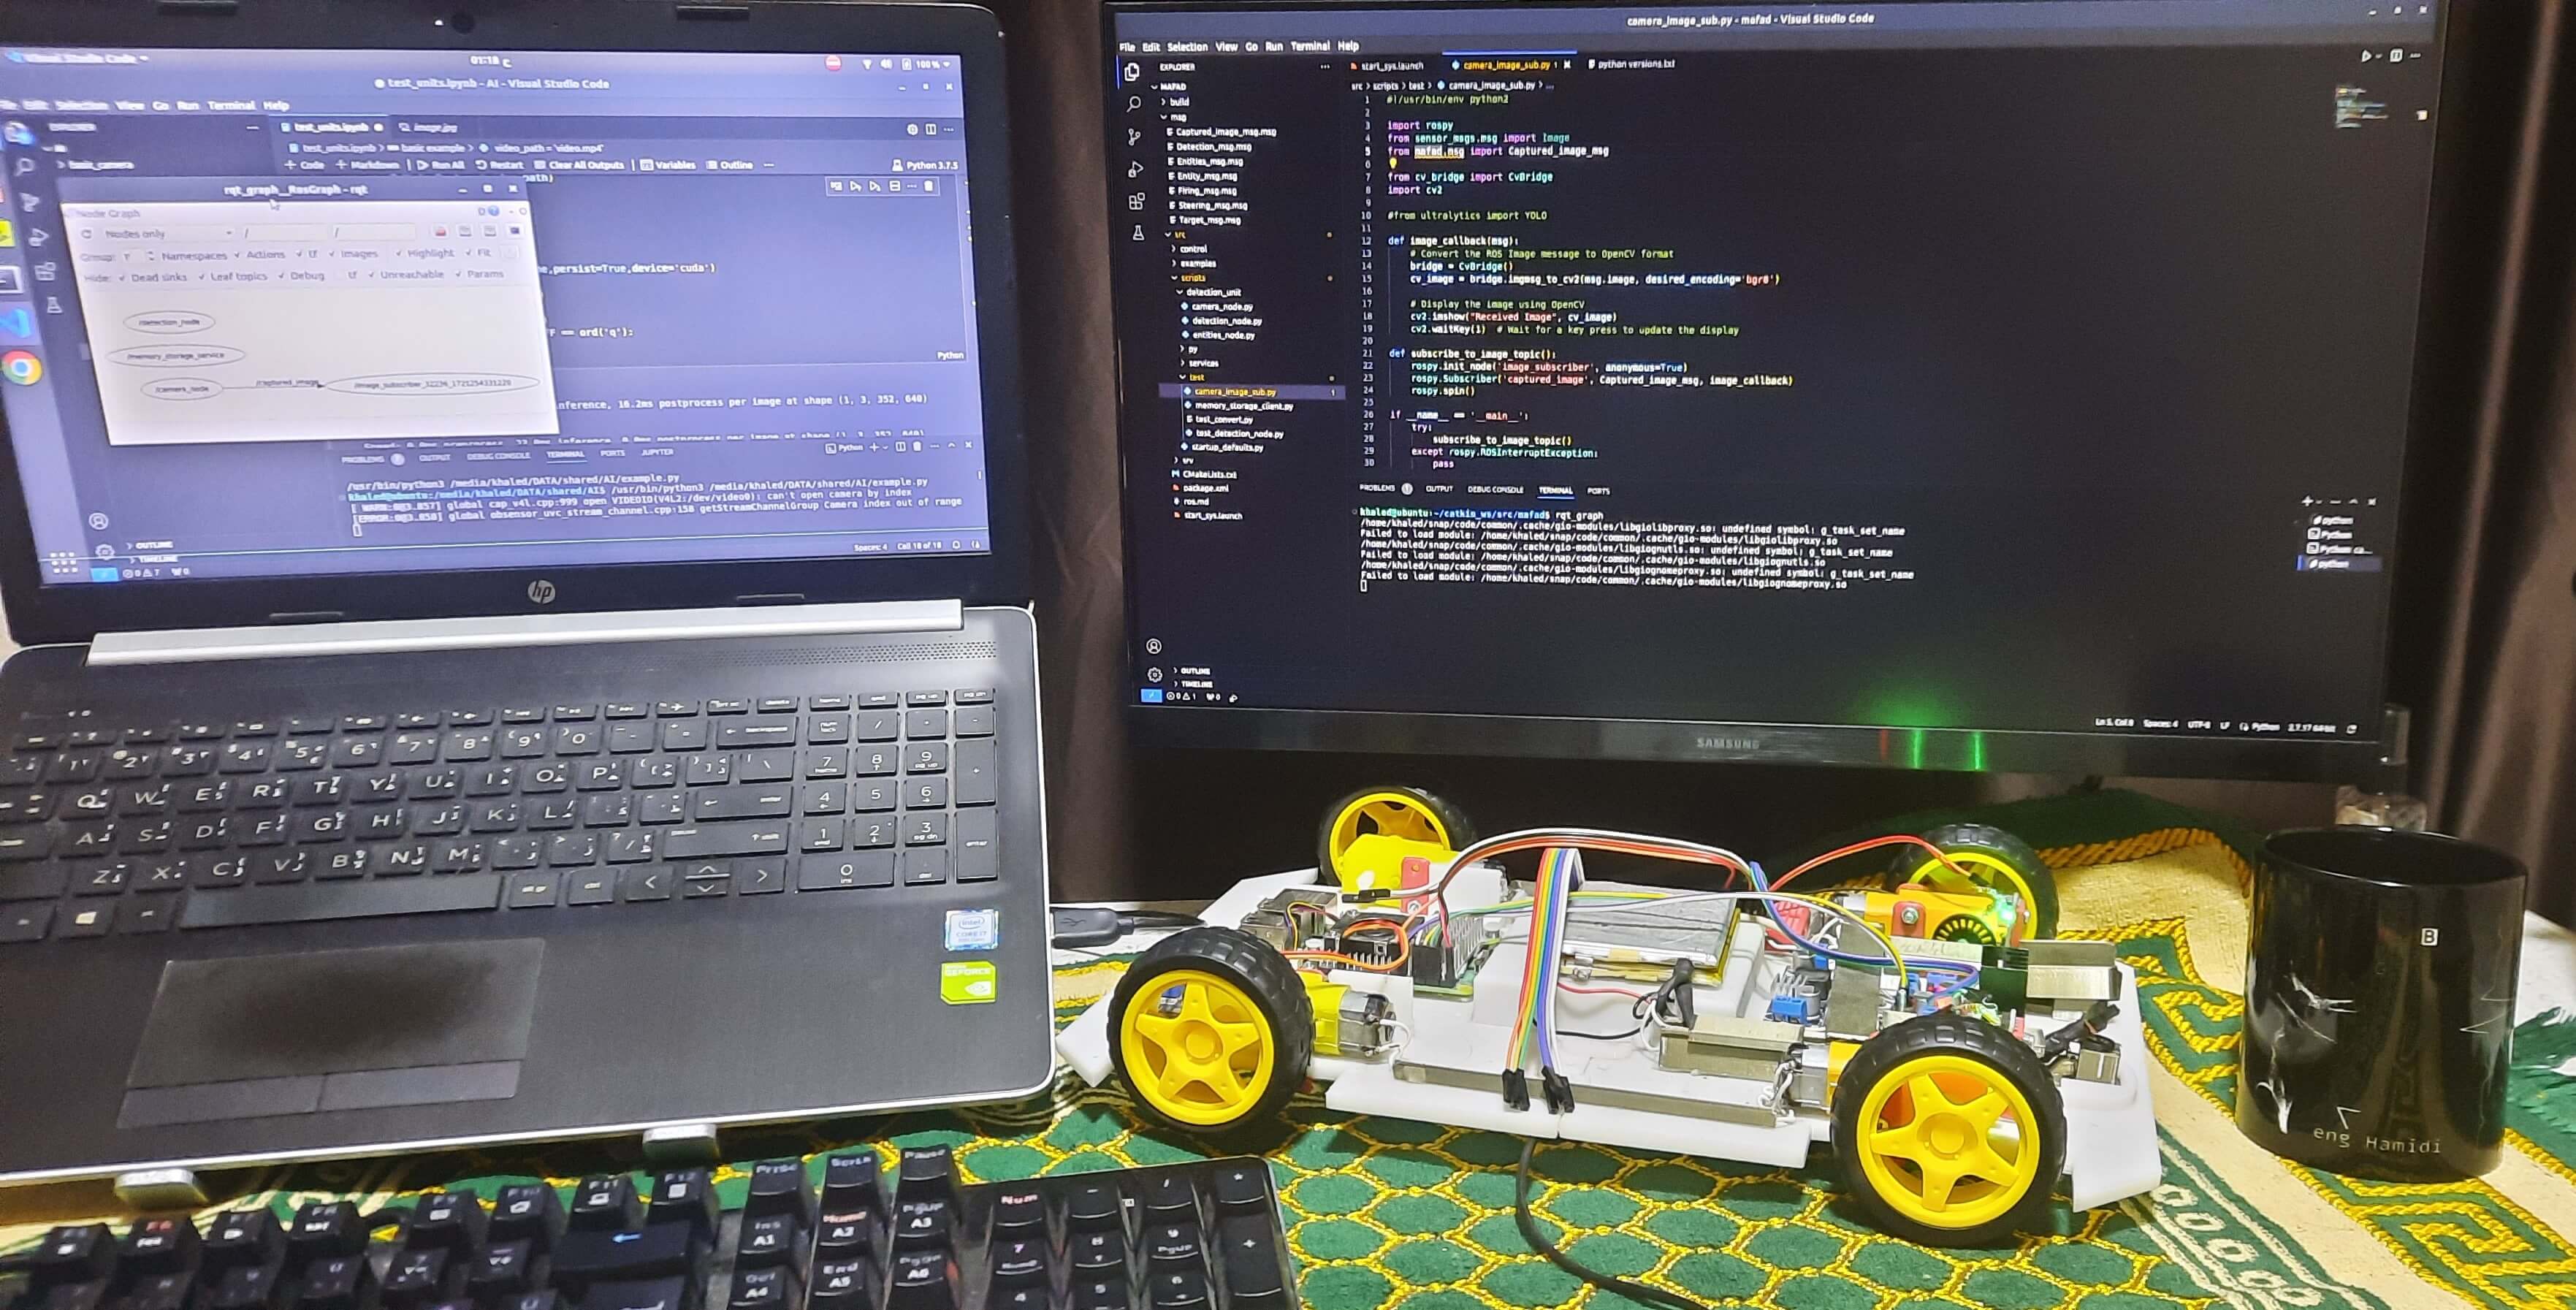
The robot is built entirely by hand, from choosing the motors and sensors to designing the control board and writing the code. Its key feature is the intelligent longitudinal control system, which lets it accelerate, brake and hold its speed fully on its own.
- Raspberry Pi as the brain of the robot
- Real-time speed and acceleration sensing
- Mechanically tuned four-wheel drive
- FLC-PID algorithm running directly on the hardware
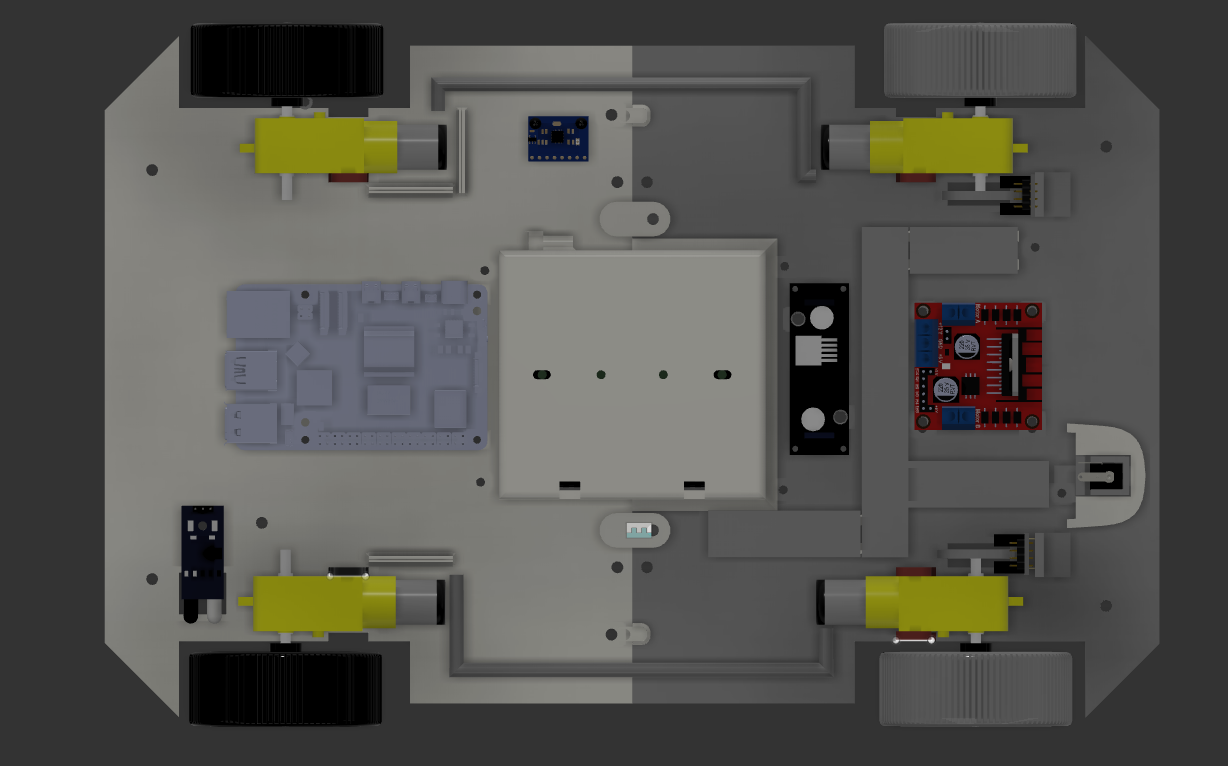
Internal layout
Longitudinal control — the heart of the robot
What sets this robot apart is not just how it is built, but the intelligence inside it. The FLC-PID longitudinal controller makes it think before it moves: it computes the target speed, adjusts motor torque, and stays stable even in less-than-ideal conditions.
The build journey
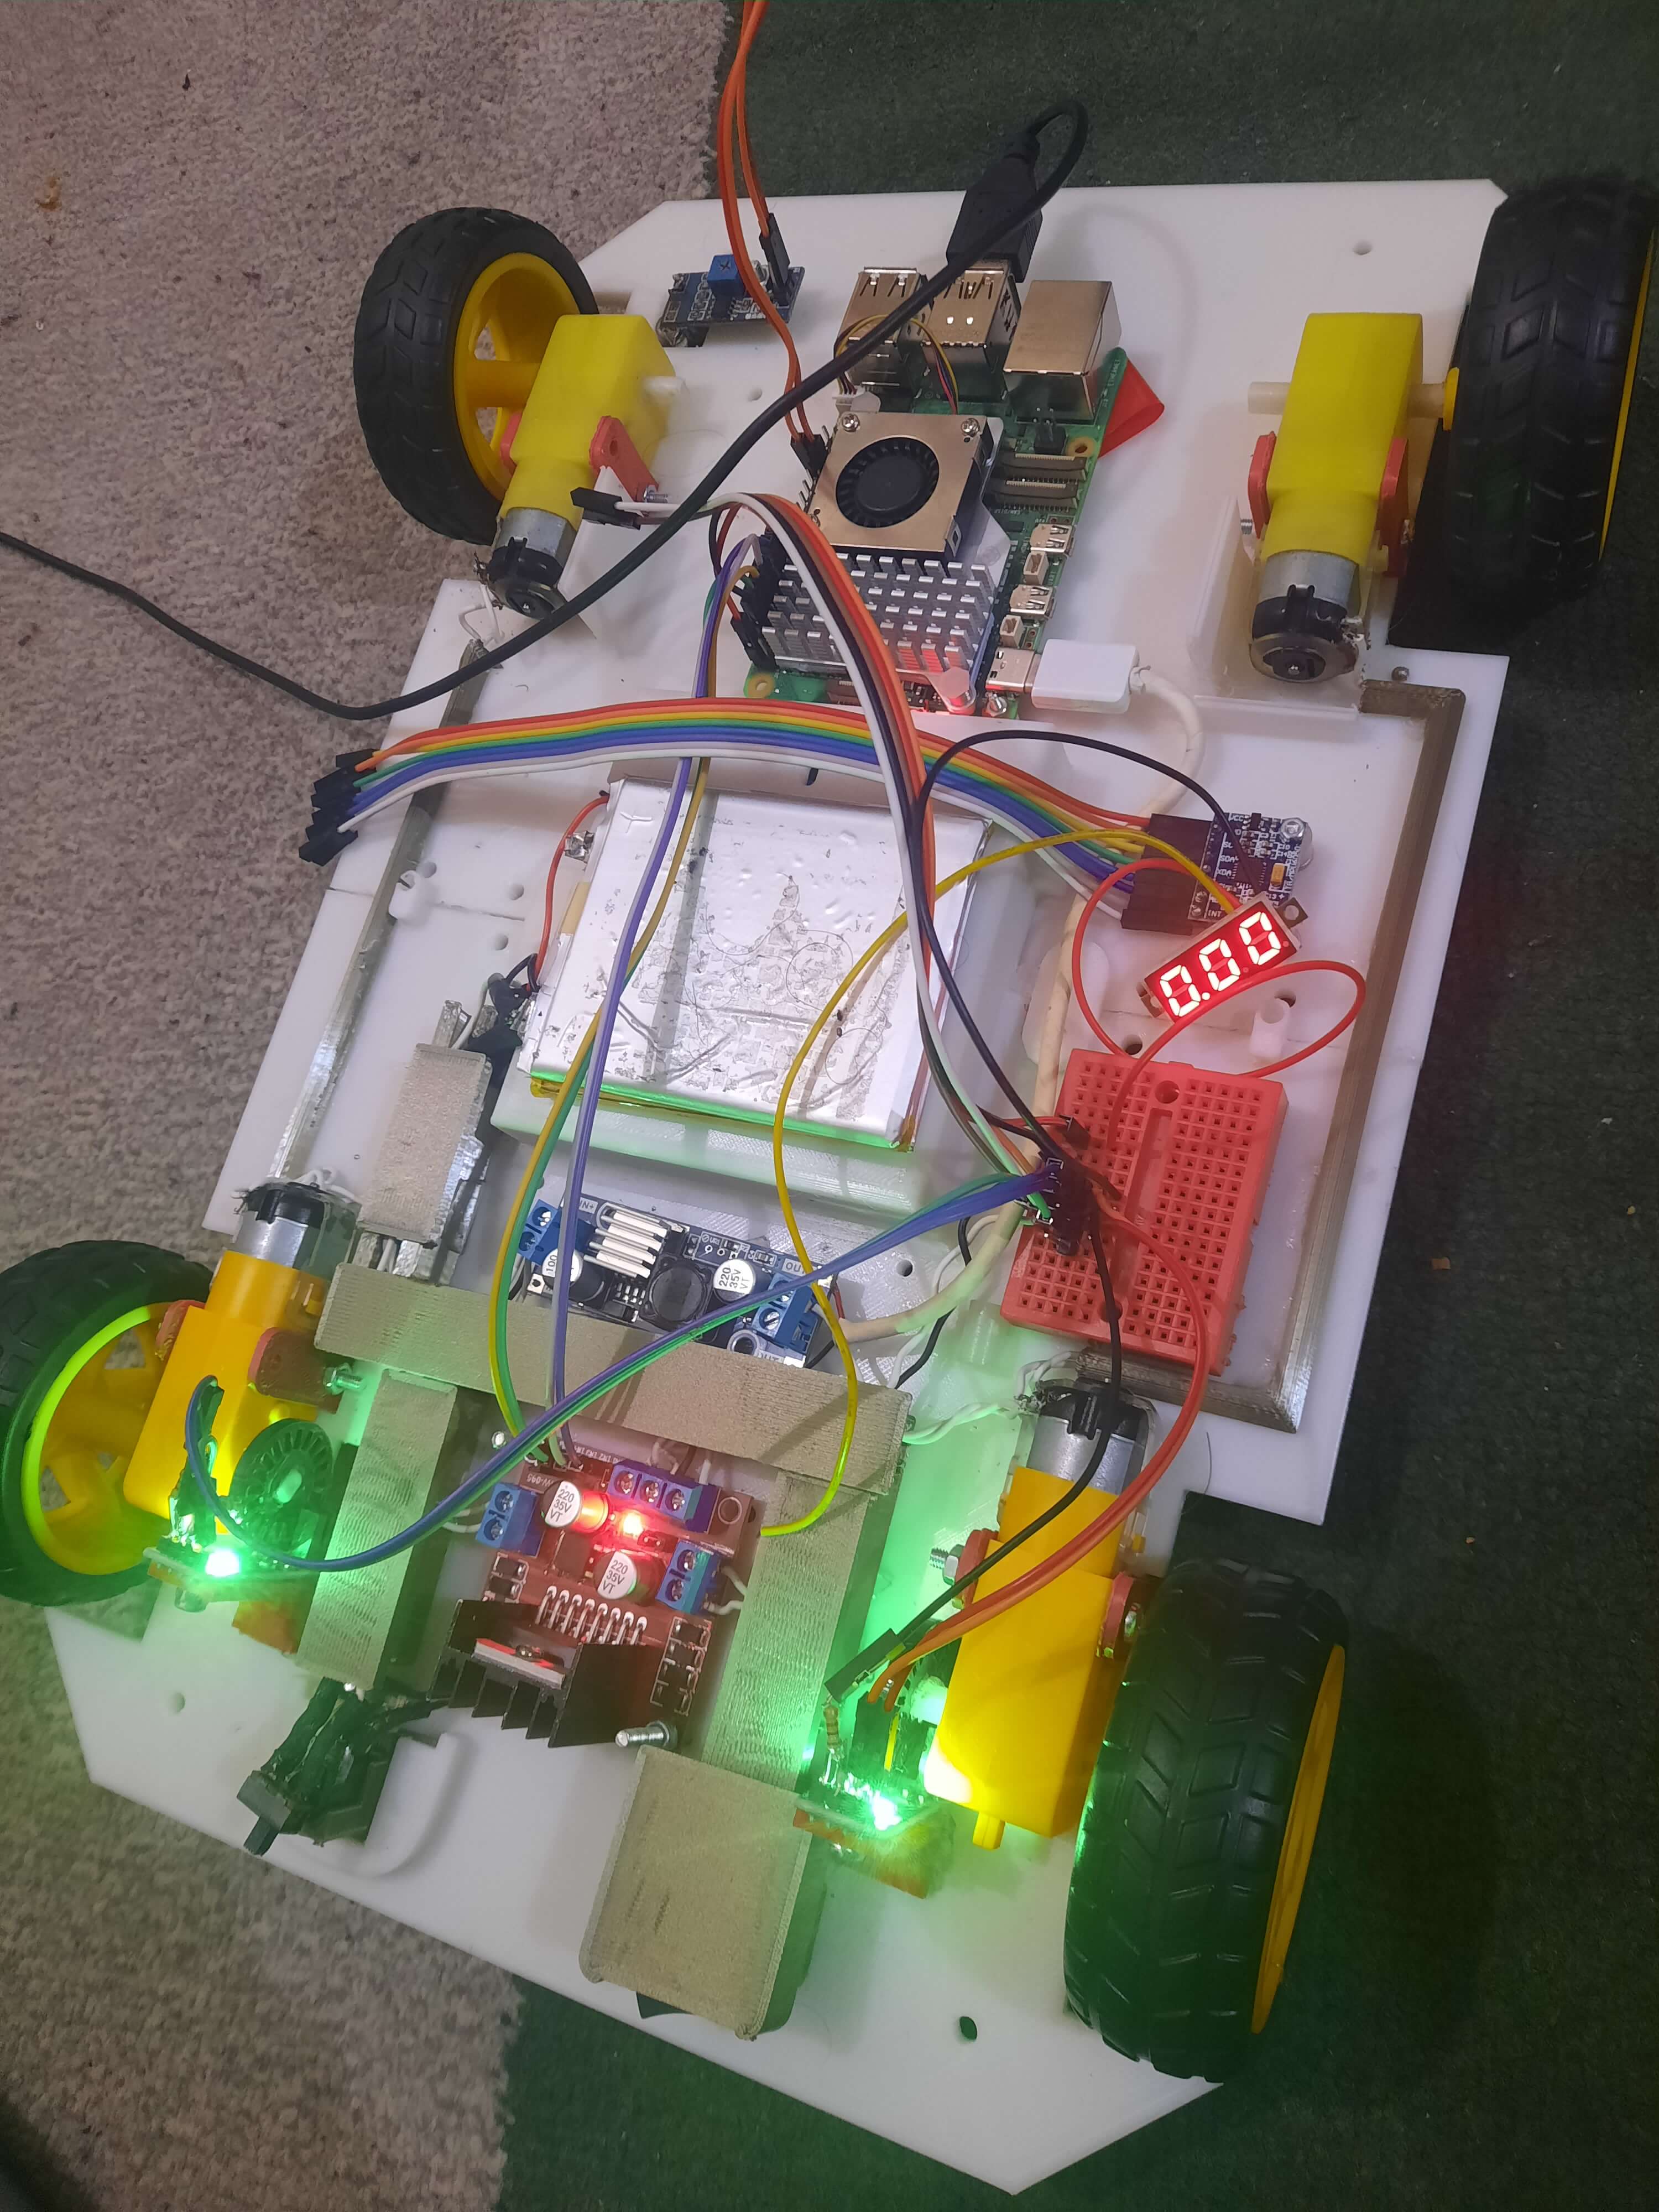
From an idea on paper to a moving robot
It started with the chassis design, went through many rounds of changes and retries, and ended with a robot that drives on its own.
Simulation in MATLAB/Simulink came first to validate the algorithm; then the real implementation on the Raspberry Pi proved that what works in simulation also works in reality.
The final result