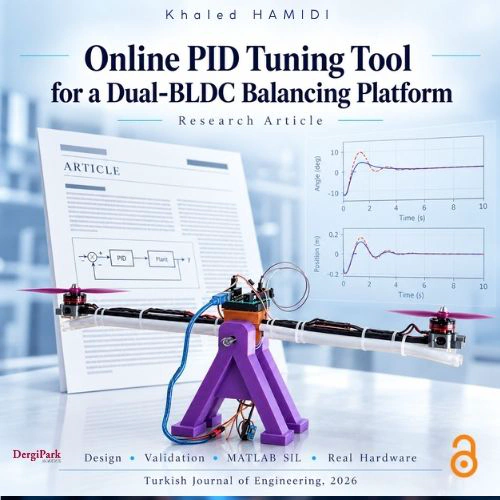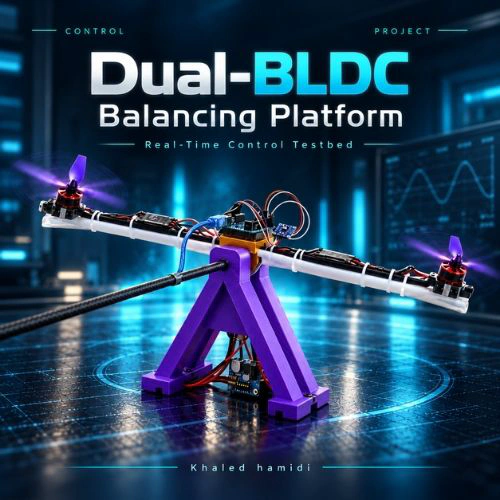
Dual-BLDC Balancing Platform: Designing an Unstable Plant to Test Real-Time Control
A seesaw balancing platform driven by two BLDC motors, designed in Fusion 360, 3D-printed and stabilized with an …
A seesaw balancing platform driven by two BLDC motors, designed in Fusion 360, 3D-printed and stabilized with an …
My peer-reviewed research article in the Turkish Journal of Engineering (Vol. 10, No. 3, 2026). It presents a …
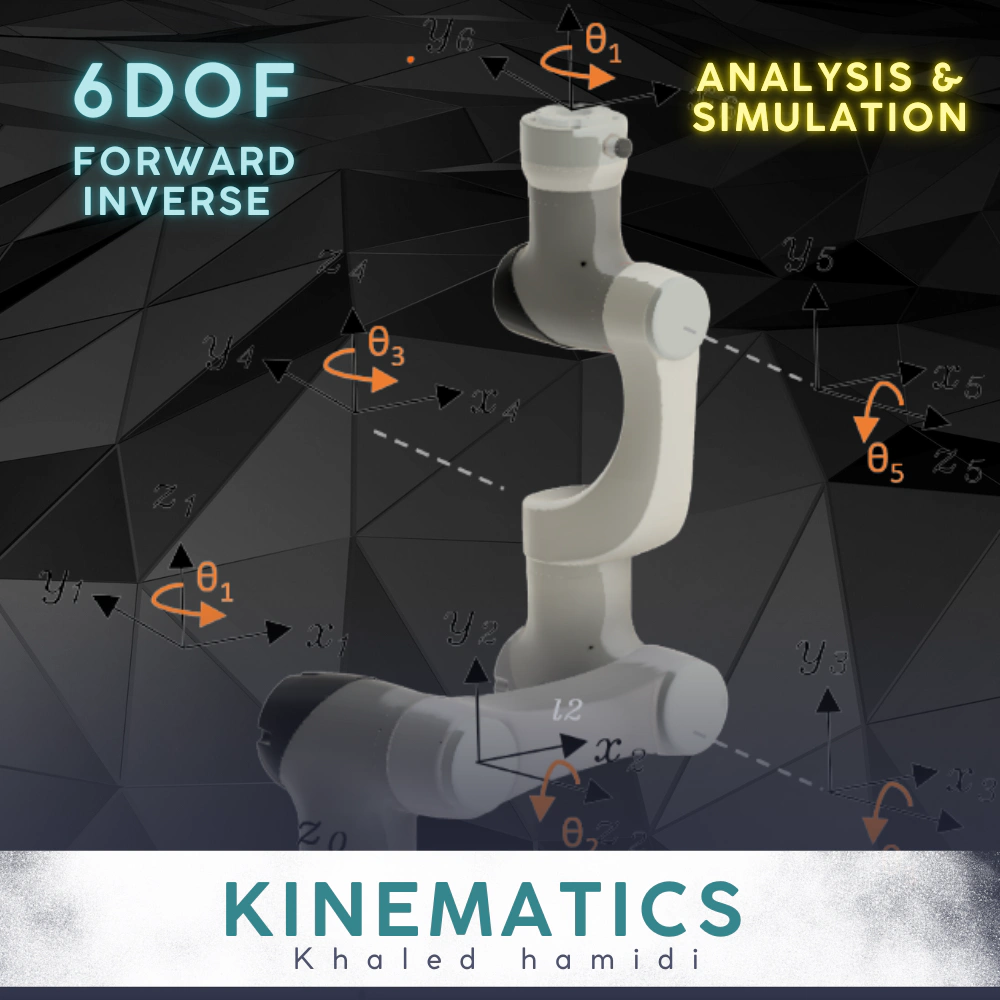
This study introduces the forward and inverse kinematics of the Collaborative Robot E15, a 6R Industrial Robot by Han's …
A peer-reviewed research paper presenting the design and manufacturing of an open-source electro-pneumatic filling …
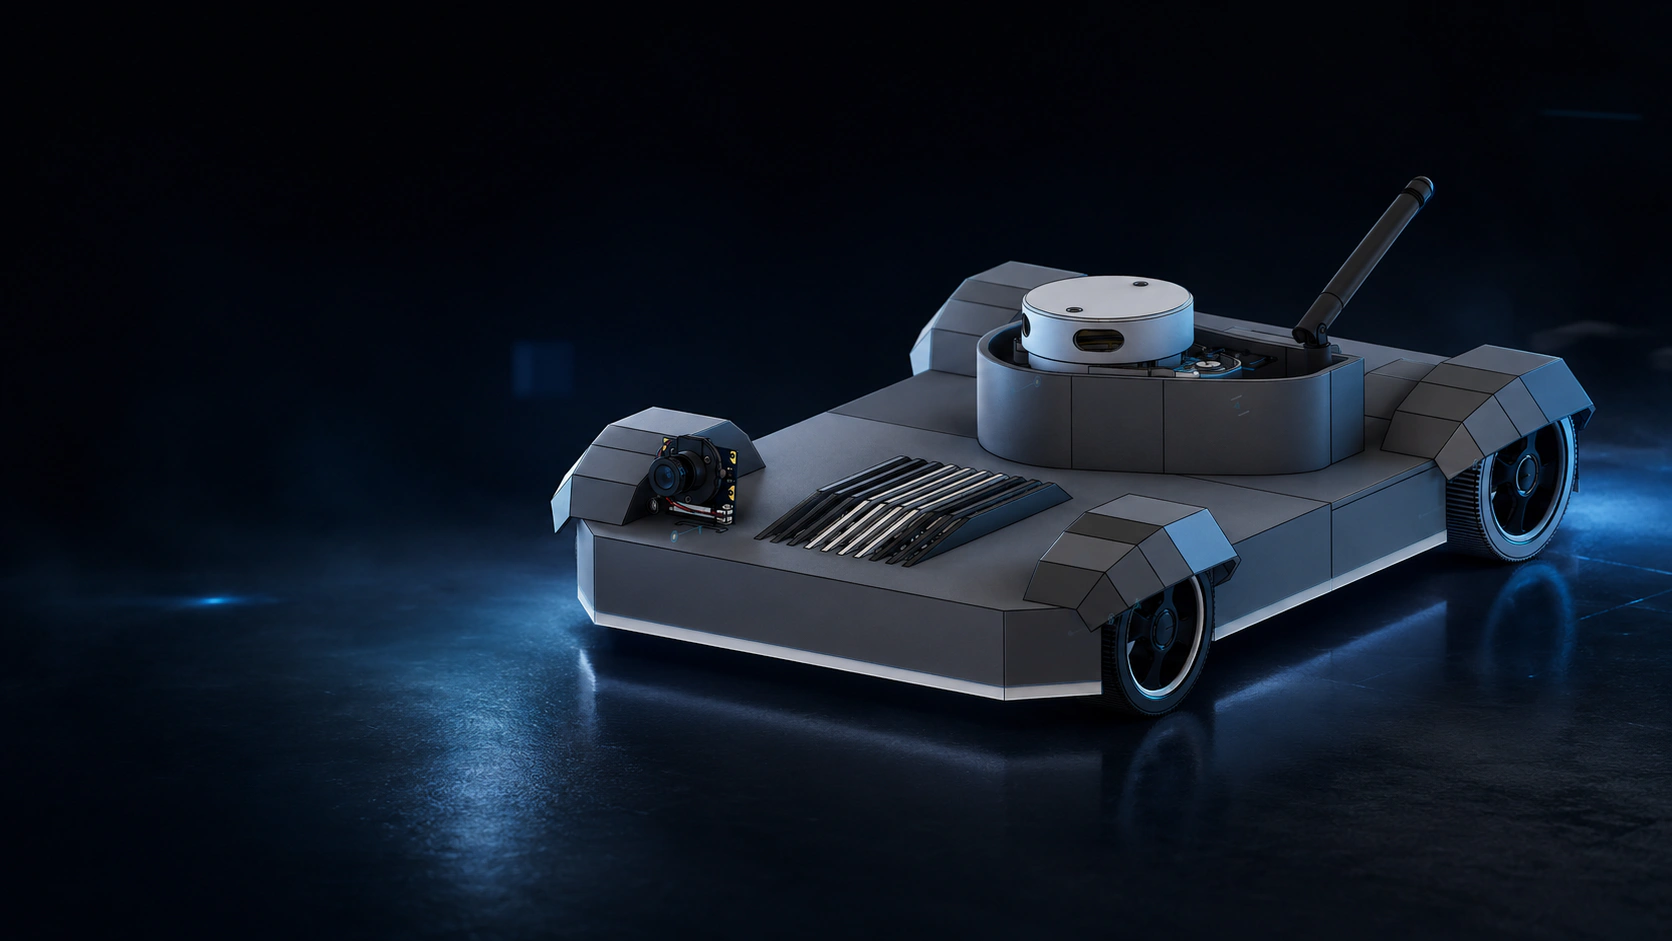
A robot built from scratch, equipped with an intelligent longitudinal control system using Fuzzy Logic and FLC-PID for …
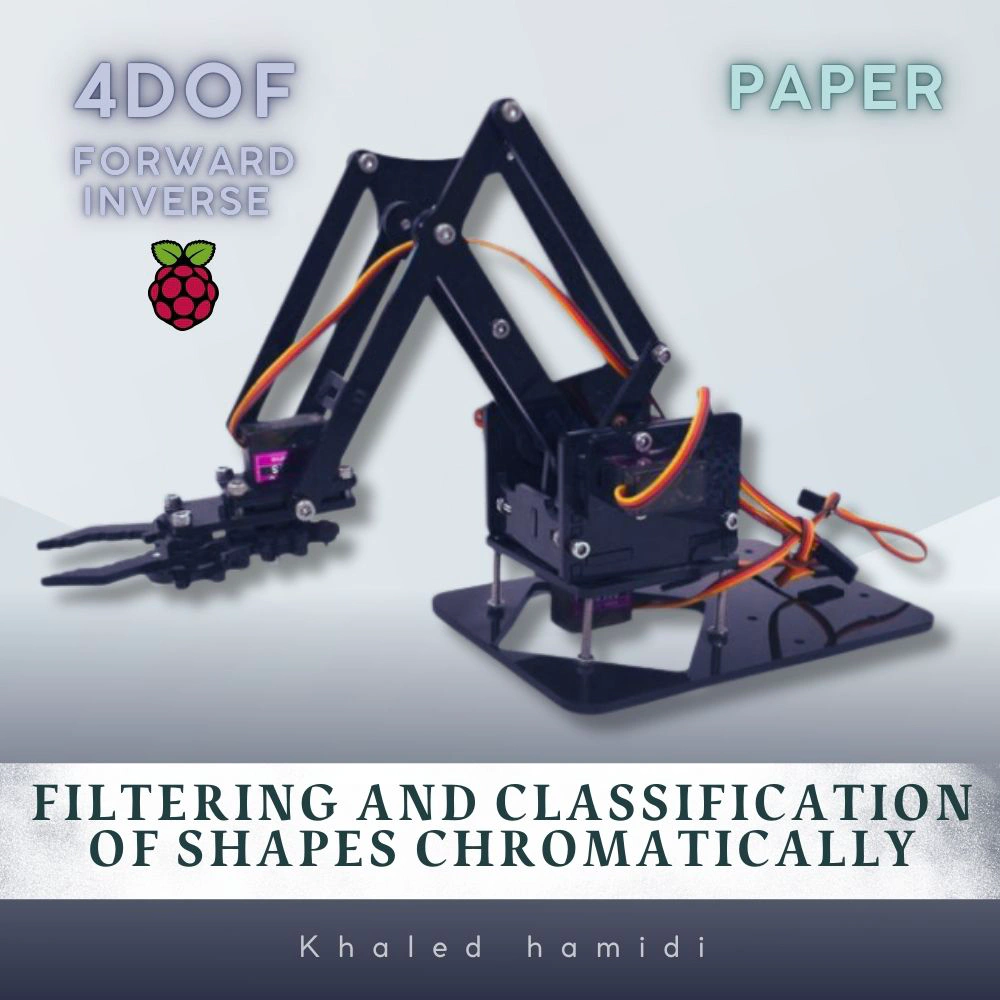
A smart approach for real-time inspection and selection of objects in continuous flow using image processing and a …
Secured TÜBİTAK funding for an autonomous mobile robot R&D project.